- Go 81.5%
- JavaScript 15.1%
- Rust 2.2%
- Go Template 0.5%
- Makefile 0.3%
- Other 0.4%
 7c5268c119 A symlink pointing at a folder that is already part of the current branch of the walk (e.g. `music/tracks/music -> ..`) made the scanner walk the same folders again and again, re-adding the same files until the OS hit its recursion or path limits. Each folder now carries its resolved path, with symlinks followed, and the walk keeps the resolved paths of the branch it is currently in. A child whose resolved path is already in that branch is a cycle and is skipped. The set is per branch rather than global, so two sibling folders linking to the same target are both walked: that is the same folder reached twice, not a loop. Resolution uses the storage's own resolver where the filesystem is backed by a real one, and falls back to following the link chain with fs.ReadLink, which keeps the comparison inside the FS-relative path space. The tests give the walk a deadline and a folder cap, because an undetected cycle does not fail, it runs forever. Verified both ways: green with the detection, and failing on the deadline without it. Fixes #5334 Signed-off-by: Junker der Provinz <133605895+junkerderprovinz@users.noreply.github.com> |
||
|---|---|---|
| .devcontainer | ||
| .github | ||
| adapters | ||
| api | ||
| cmd | ||
| conf | ||
| consts | ||
| contrib | ||
| core | ||
| db | ||
| git | ||
| log | ||
| model | ||
| persistence | ||
| plugins | ||
| release | ||
| resources | ||
| scanner | ||
| scheduler | ||
| scripts | ||
| server | ||
| tests | ||
| ui | ||
| utils | ||
| .dockerignore | ||
| .git-blame-ignore-revs | ||
| .gitignore | ||
| .golangci.yml | ||
| .nvmrc | ||
| .octocov.yml | ||
| CODE_OF_CONDUCT.md | ||
| context7.json | ||
| CONTRIBUTING.md | ||
| Dockerfile | ||
| go.mod | ||
| go.sum | ||
| LICENSE | ||
| main.go | ||
| Makefile | ||
| Procfile.dev | ||
| README.md | ||
| reflex.conf | ||

Navidrome Music Server 



Navidrome is an open source web-based music collection server and streamer. It gives you freedom to listen to your music collection from any browser or mobile device. It's like your personal Spotify!
Note: The master branch may be in an unstable or even broken state during development.
Please use releases instead of
the master branch in order to get a stable set of binaries.
Check out our Live Demo!
Any feedback is welcome! If you need/want a new feature, find a bug or think of any way to improve Navidrome, please file a GitHub issue or join the discussion in our Subreddit. If you want to contribute to the project in any other way (ui/backend dev, translations, themes), please join the chat in our Discord server.
Installation
See instructions on the project's website
Cloud Hosting
PikaPods has partnered with us to offer you an officially supported, cloud-hosted solution. A share of the revenue helps fund the development of Navidrome at no additional cost for you.

Features
- Handles very large music collections
- Streams virtually any audio format available
- Reads and uses all your beautifully curated metadata
- Great support for compilations (Various Artists albums) and box sets (multi-disc albums)
- Multi-user, each user has their own play counts, playlists, favourites, etc...
- Very low resource usage
- Multi-platform, runs on macOS, Linux and Windows. Docker images are also provided
- Ready to use binaries for all major platforms, including Raspberry Pi
- Automatically monitors your library for changes, importing new files and reloading new metadata
- Supports lyrics from sidecar .ttml, .yaml/.yml Lyricsfile, .elrc, .lrc, .srt, .txt files and embedded TTML, Enhanced LRC, LRC, SRT, and plain-text tags (via
lyricspriority) - Themeable, modern and responsive Web interface based on Material UI
- Compatible with all Subsonic/Madsonic/Airsonic clients
- Transcoding on the fly. Can be set per user/player. Opus encoding is supported
- Translated to various languages
Translations
Navidrome uses POEditor for translations, and we are always looking for more contributors
Documentation
All documentation can be found in the project's website: https://www.navidrome.org/docs. Here are some useful direct links:
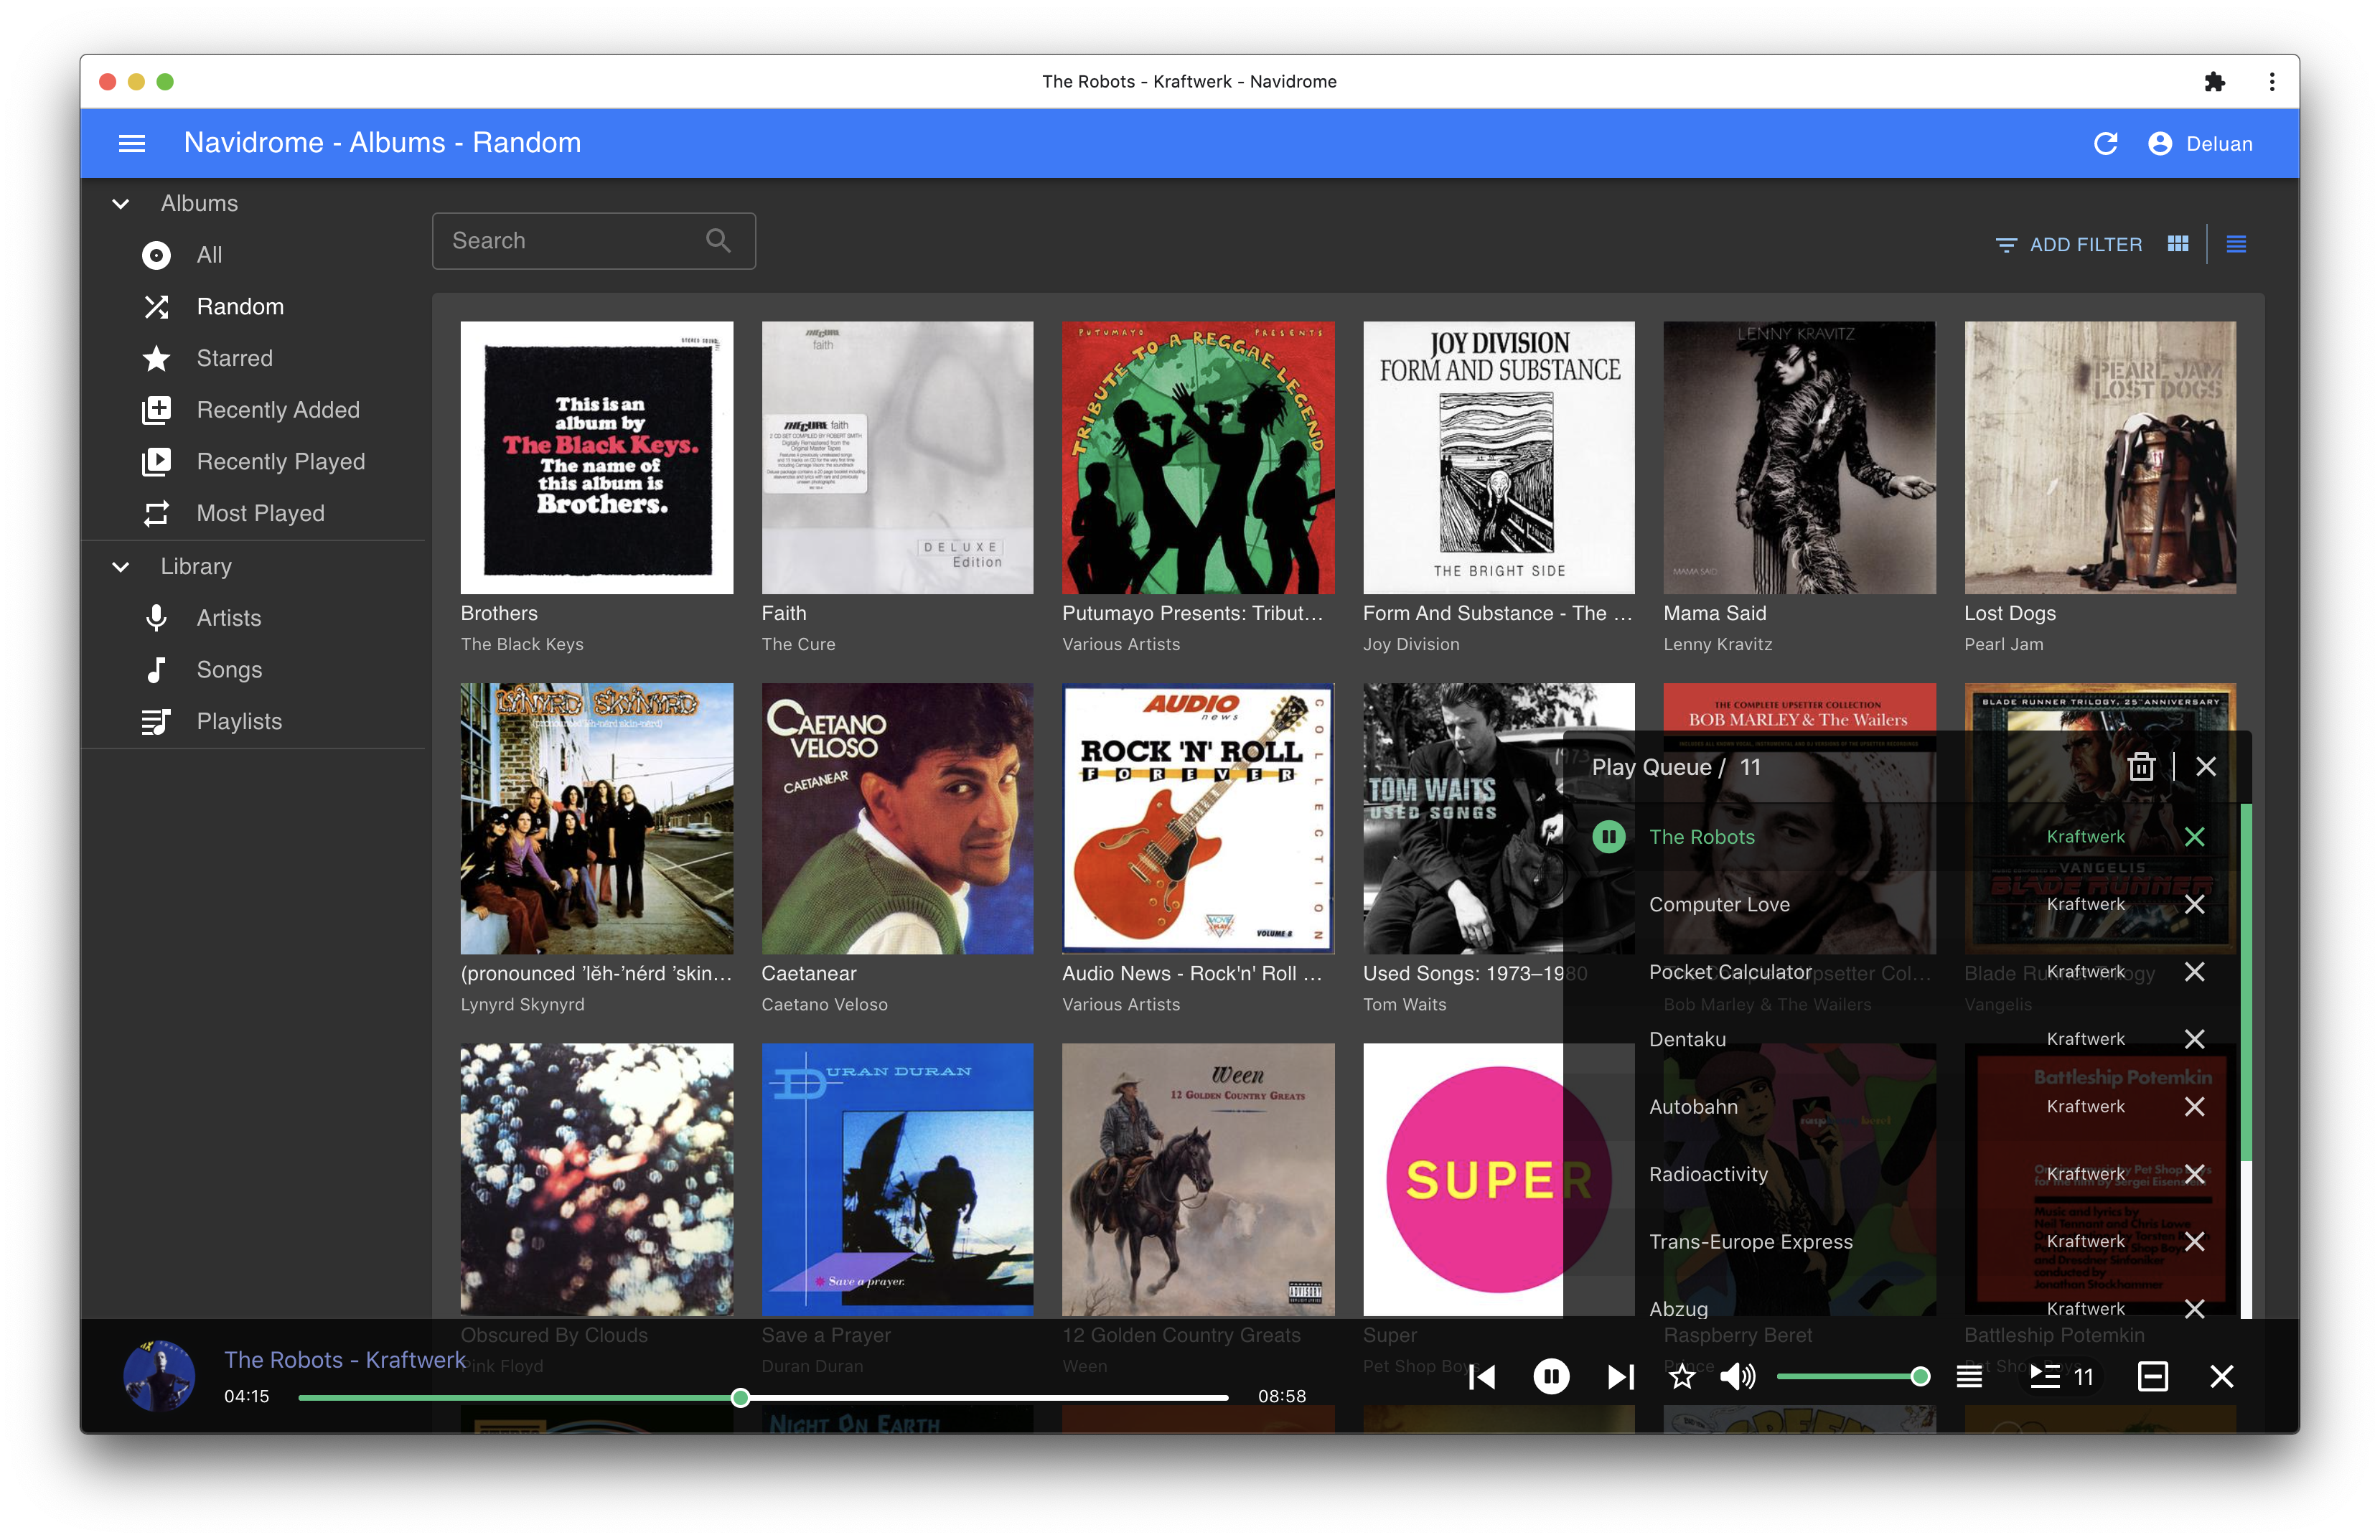
Screenshots